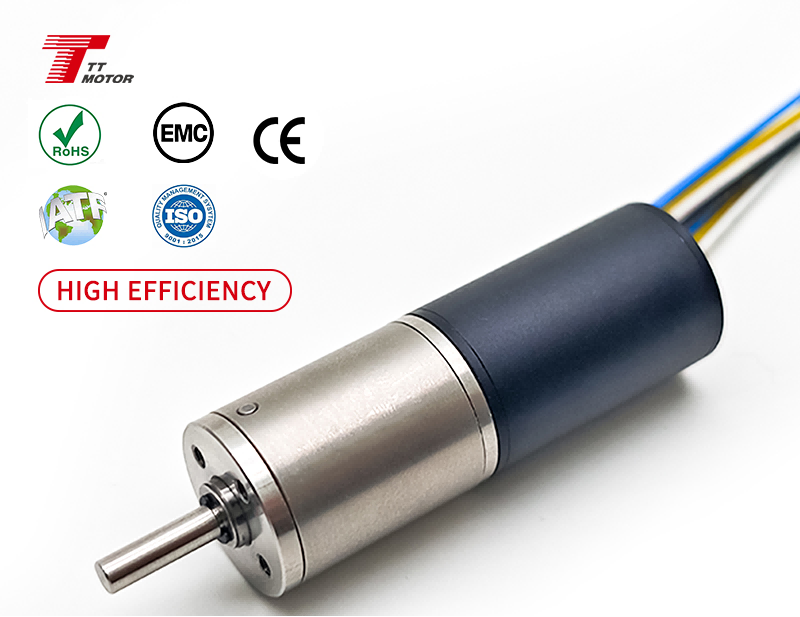
The GMP16-TBC1625, an integrated actuator consisting of a brushless coreless motor and precision planetary gearbox, has become a highly reliable and compact driving solution for advanced robotic fingers. With a total length of only 41 mm, the module achieves excellent miniaturization and can be directly embedded inside the finger structure, greatly improving the integration, flexibility and appearance of robotic end-effectors. It operates at a rated voltage of 24 V, with a no-load speed of 1060 rpm and rated torque of no less than 50 mNm, providing stable and controllable power output for delicate grasping and precise movement.
The brushless coreless motor design eliminates cogging effect, reduces rotational inertia and delivers fast response, low noise and long service life. Combined with a high-efficiency planetary gearbox, the system converts high speed into strong and stable torque while maintaining low backlash and smooth transmission. This combination ensures that robotic fingers can perform both light, gentle gripping of fragile items and firm clamping of objects with consistent accuracy.
The GMP16-TBC1625 is widely used in humanoid robotic hands, rehabilitation robots, prosthetic hands, industrial micro-grippers and intelligent operating devices. It supports flexible operations such as picking tiny components, manipulating tools, grabbing daily objects and assisting rehabilitation training.
By perfectly balancing miniaturization, torque performance and dynamic response, the GMP16-TBC1625 effectively solves the challenges of limited space and high-precision actuation in robotic fingers. It significantly enhances the bionic performance and practicality of modern robots, making it an ideal component for developing smarter, more compact and more versatile robotic systems.
Post time: Nov-12-2026